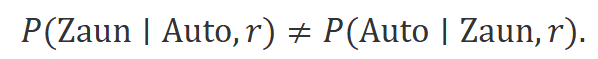
Below is a self-contained maXbox / Object Pascal demo that implements contextual scoring for correlated objects. It does not require a neural network or image library: it assumes that a detector has already produced object candidates such a...
Below is a self-contained maXbox / Object Pascal demo that implements contextual scoring for correlated objects.
It does not require a neural network or image library: it assumes that a detector has already produced object candidates such as car, fence, road, or rail, each with a local confidence and a bounding box. The program then builds pairwise spatial relations and iteratively updates each candidate’s probability using learned-like correlation rules.
maXbox is an Object Pascal scripting environment based on PascalScript, intended for experimenting with algorithms and executable scripts in one application.[blogs.embarcadero][sourceforge]
What it demonstrates
The program models:
A local detector confidence for every candidate.
Pairwise relations based on:
distance between bounding-box centers,
relative horizontal/vertical position,
overlap,
relative size.
Correlation rules such as:
road → car is supportive if the car lies on/near the road,
car → fence is mildly supportive only at short range,
rail → train is strongly supportive when aligned and close,
fence → car is weaker than car → fence in this sample.
Iterative belief propagation-like rescoring:
Each candidate receives messages from nearby candidates.
A context message changes the candidate’s original detector log-odds.
The local classifier remains the principal source of evidence.
The relation is deliberately directional: Auto → Zaun and Zaun → Auto may have different weights. This reflects the fact that conditional probabilities are asymmetric:
maXbox source code
Paste the following into a new maXbox script and run it. It prints the initial and context-adjusted confidences to the console/log.
program CorrelatedObjectsDemo;
const
MAX_OBJECTS = 12;
MAX_ITERATIONS = 7;
type
TObjectClass = (
ocUnknown,
ocCar,
ocFence,
ocRoad,
ocRail,
ocTrain,
ocVegetation
);
TObjectCandidate = record
Name: string;
ClassId: TObjectClass;
LocalProbability: Double;
Probability: Double;
NewProbability: Double;
X: Double;
Y: Double;
W: Double;
H: Double;
end;
function ClassName(AClass: TObjectClass): string;
begin
case AClass of
ocCar: Result:= 'Car';
ocFence: Result:= 'Fence';
ocRoad: Result:= 'Road';
ocRail: Result:= 'Rail';
ocTrain: Result:= 'Train';
ocVegetation: Result:= 'Vegetation';
else
Result:= 'Unknown';
end;
end;
function Clamp(Value, LowValue, HighValue: Double): Double;
begin
Result:= Value;
if Result HighValue then
Result:= HighValue;
end;
function Sigmoid(Value: Double): Double;
begin
if Value > 30.0 then begin
Result:= 1.0;
Exit;
end;
if Value LeftEdge then
LeftEdge:= B.X;
RightEdge:= A.X + A.W;
if B.X + B.W TopEdge then
TopEdge:= B.Y;
BottomEdge:= A.Y + A.H;
if B.Y + B.H = MaxDistance then
Result:= 0.0
else
Result:= 1.0 - D / MaxDistance;
end;
function IsBInFrontOfA(const A, B: TObjectCandidate): Boolean;
begin
{ Image coordinates: greater Y means lower in the picture.
B is considered "in front" if it is lower than A. }
Result:= CenterY(B) > CenterY(A);
end;
function RelationQuality(const Target, Evidence: TObjectCandidate): Double;
var
NearValue, HOverlap, VOverlap: Double;
begin
NearValue:= Nearness(Target, Evidence, 180.0);
HOverlap:= HorizontalOverlap(Target, Evidence);
VOverlap:= VerticalOverlap(Target, Evidence);
Result:= NearValue;
{ Special geometries can strengthen a relation. }
if (Target.ClassId = ocCar) and (Evidence.ClassId = ocRoad) then
Result:= Clamp(0.55 * NearValue + 0.45 * HOverlap, 0.0, 1.0);
if (Target.ClassId = ocTrain) and (Evidence.ClassId = ocRail) then
Result:= Clamp(0.55 * NearValue + 0.45 * HOverlap, 0.0, 1.0);
if (Target.ClassId = ocFence) and (Evidence.ClassId = ocCar) then begin
Result:= 0.70 * NearValue;
if IsBInFrontOfA(Target, Evidence) then
Result:= Result + 0.15;
Result:= Clamp(Result, 0.0, 1.0);
end;
if (Target.ClassId = ocCar) and (Evidence.ClassId = ocFence) then
Result:= Clamp(0.60 * NearValue + 0.20 * VOverlap, 0.0, 1.0);
end;
function CorrelationWeight(TargetClass, EvidenceClass: TObjectClass): Double;
begin
Result:= 0.0;
{ Directional contextual weights.
Positive = evidence supports the target hypothesis.
Negative = evidence weakens the target hypothesis. }
if (TargetClass = ocCar) and (EvidenceClass = ocRoad) then
Result:= 1.30;
if (TargetClass = ocRoad) and (EvidenceClass = ocCar) then
Result:= 0.35;
if (TargetClass = ocFence) and (EvidenceClass = ocCar) then
Result:= 0.65;
if (TargetClass = ocCar) and (EvidenceClass = ocFence) then
Result:= 0.25;
if (TargetClass = ocTrain) and (EvidenceClass = ocRail) then
Result:= 1.60;
if (TargetClass = ocRail) and (EvidenceClass = ocTrain) then
Result:= 0.55;
if (TargetClass = ocTrain) and (EvidenceClass = ocRoad) then
Result:= -0.55;
if (TargetClass = ocRail) and (EvidenceClass = ocVegetation) then
Result:= -0.20;
end;
procedure PrintObjects(const Title: string;
const Objects: array of TObjectCandidate; Count: Integer);
var
I: Integer;
begin
Writeln('');
Writeln(Title);
Writeln('-------------------------------------------------------------');
for I:= 0 to Count - 1 do begin
Writeln(
Objects[I].Name + ' class=' + ClassName(Objects[I].ClassId) +
' local=' + FloatToStrF(Objects[I].LocalProbability, ffFixed, 8, 3) +
' final=' + FloatToStrF(Objects[I].Probability, ffFixed, 8, 3) +
' box=(' + FloatToStrF(Objects[I].X, ffFixed, 8, 0) + ',' +
FloatToStrF(Objects[I].Y, ffFixed, 8, 0) + ',' +
FloatToStrF(Objects[I].W, ffFixed, 8, 0) + ',' +
FloatToStrF(Objects[I].H, ffFixed, 8, 0) + ')'
);
end;
end;
procedure ExplainRelations(const Objects: array of TObjectCandidate;
Count: Integer);
var
I, J: Integer;
Weight, Quality, Message: Double;
begin
Writeln('');
Writeln('Relevant contextual relations');
Writeln('-------------------------------------------------------------');
for I:= 0 to Count - 1 do begin
for J:= 0 to Count - 1 do begin
if I J then begin
Weight:= CorrelationWeight(Objects[I].ClassId, Objects[J].ClassId);
if Weight 0.0 then begin
Quality:= RelationQuality(Objects[I], Objects[J]);
Message:= Weight * Quality * Objects[J].Probability;
if Abs(Message) > 0.02 then
Writeln(
Objects[J].Name + ' -> ' + Objects[I].Name +
' weight=' + FloatToStrF(Weight, ffFixed, 8, 2) +
' relation=' + FloatToStrF(Quality, ffFixed, 8, 2) +
' evidence=' + FloatToStrF(Objects[J].Probability, ffFixed, 8, 2) +
' message=' + FloatToStrF(Message, ffFixed, 8, 3)
);
end;
end;
end;
end;
end;
type TCand_Objects = array[0..MAX_OBJECTS - 1] of TObjectCandidate;
const
CONTEXT_STRENGTH = 0.85;
DAMPING = 0.55;
procedure UpdateProbabilities(var Objects: TCand_Objects; {array of TObjectCandidate;}
Count, Iterations: Integer);
var
I, J, Step: Integer;
ContextMessage, Weight, Quality: Double;
BaseLogit, UpdatedLogit: Double;
begin
for Step:= 1 to Iterations do begin
for I:= 0 to Count - 1 do begin
ContextMessage := 0.0;
for J:= 0 to Count - 1 do begin
if I J then begin
Weight := CorrelationWeight(
Objects[I].ClassId,
Objects[J].ClassId
);
if Weight 0.0 then begin
Quality:= RelationQuality(Objects[I], Objects[J]);
{ Strong evidence has more influence.
The relation quality goes to zero for distant or
geometrically implausible neighbours. }
ContextMessage:= ContextMessage +
Weight * Quality * Objects[J].Probability;
end;
end;
end;
{ The local detector remains the anchor.
Context adjusts its log-odds rather than replacing it. }
BaseLogit:= Logit(Objects[I].LocalProbability);
UpdatedLogit:= BaseLogit + CONTEXT_STRENGTH * ContextMessage;
Objects[I].NewProbability := Sigmoid(UpdatedLogit);
end;
{ Damping avoids unstable oscillation during iterations. }
for I:= 0 to Count - 1 do
Objects[I].Probability :=
DAMPING * Objects[I].NewProbability +
(1.0 - DAMPING) * Objects[I].Probability;
Writeln('');
Writeln('Iteration ' + IntToStr(Step));
for I:= 0 to Count - 1 do
Writeln(
Objects[I].Name + ': ' +
FloatToStrF(Objects[I].Probability, ffFixed, 8, 3)
);
end;
end;
//type TCand_Objects = array[0..MAX_OBJECTS - 1] of TObjectCandidate;
var
Objects: TCand_Objects; //array[0..MAX_OBJECTS - 1] of TObjectCandidate;
Count, I: Integer;
begin //@main
Writeln('Correlated Objects / maXbox Contextual Rescoring Demo');
Writeln('=============================================================');
Count:= 6;
{ Candidate 0: weak local fence detection. }
Objects[0].Name:= 'FenceCandidate';
Objects[0].ClassId := ocFence;
Objects[0].LocalProbability:= 0.48;
Objects[0].X:= 120;
Objects[0].Y:= 130;
Objects[0].W:= 150;
Objects[0].H:= 18;
{ Candidate 1: a strong car detection in front of the fence. }
Objects[1].Name:= 'CarCandidate';
Objects[1].ClassId := ocCar;
Objects[1].LocalProbability := 0.93;
Objects[1].X:= 160;
Objects[1].Y:= 160;
Objects[1].W:= 54;
Objects[1].H:= 30;
{ Candidate 2: road context supporting the car. }
Objects[2].Name:= 'RoadCandidate';
Objects[2].ClassId:= ocRoad;
Objects[2].LocalProbability:= 0.89;
Objects[2].X:= 75;
Objects[2].Y:= 150;
Objects[2].W:= 280;
Objects[2].H:= 105;
{ Candidate 3: weak train hypothesis. }
Objects[3].Name:= 'TrainCandidate';
Objects[3].ClassId:= ocTrain;
Objects[3].LocalProbability:= 0.41;
Objects[3].X:= 440;
Objects[3].Y:= 310;
Objects[3].W:= 155;
Objects[3].H:= 42;
{ Candidate 4: a strong rail detection aligned with train. }
Objects[4].Name:= 'RailCandidate';
Objects[4].ClassId:= ocRail;
Objects[4].LocalProbability:= 0.92;
Objects[4].X:= 400;
Objects[4].Y:= 325;
Objects[4].W:= 270;
Objects[4].H:= 20;
{ Candidate 5: unrelated vegetation. }
Objects[5].Name:= 'VegetationCandidate';
Objects[5].ClassId:= ocVegetation;
Objects[5].LocalProbability := 0.86;
Objects[5].X:= 720;
Objects[5].Y:= 100;
Objects[5].W:= 130;
Objects[5].H:= 190;
{ Initialize final probability from local detector probability. }
//var I: Integer;
for I:= 0 to Count - 1 do begin
Objects[I].Probability:= Objects[I].LocalProbability;
Objects[I].NewProbability:= Objects[I].LocalProbability;
end;
PrintObjects('Initial detector output', Objects, Count);
ExplainRelations(Objects, Count);
UpdateProbabilities(Objects, Count, MAX_ITERATIONS);
PrintObjects('Final probabilities after contextual rescoring',Objects,Count);
Writeln('');
Writeln('Interpretation:');
Writeln('- FenceCandidate is strengthened by the nearby confident car.');
Writeln('- CarCandidate is strongly supported by the overlapping road.');
Writeln('- TrainCandidate is strengthened by the nearby aligned rail.');
Writeln('- Distant vegetation has almost no contextual influence.');
end.
How the algorithm works
For each candidate
𝑖 i, the code starts from its local detector probability:
.
It transforms that into log-odds:
Then it adds weighted context messages from all other candidates
u ) is the directional semantic correlation weight, supplied by CorrelationWeight.
q ) is RelationQuality, a value from 0 to 1 derived from distance, overlap, and selected geometrical tests.
p is the current confidence of the evidence object.
The context-adjusted probability is:
A practical caveat
This is a compact context-rescoring model, not a trained neural net. It is useful for validating the principle, testing a rule set, or post-processing detections from a separate model such as YOLO.
For a production model, you would normally choose one of these approaches:
Train an object detector or segmenter that learns context implicitly from large receptive fields and attention.
Attach a graph neural network or relation module to detected objects; relation weights are learned end-to-end.
Use a CRF over pixels/regions when boundary-aware semantic segmentation is the main task.
Retain an explicit rule-based post-processor like this when relations must be inspectable, auditable, and easily adapted to a specific GEOINT or infrastructure domain.
pilotfiber.dl.sourceforge.net